基本信息
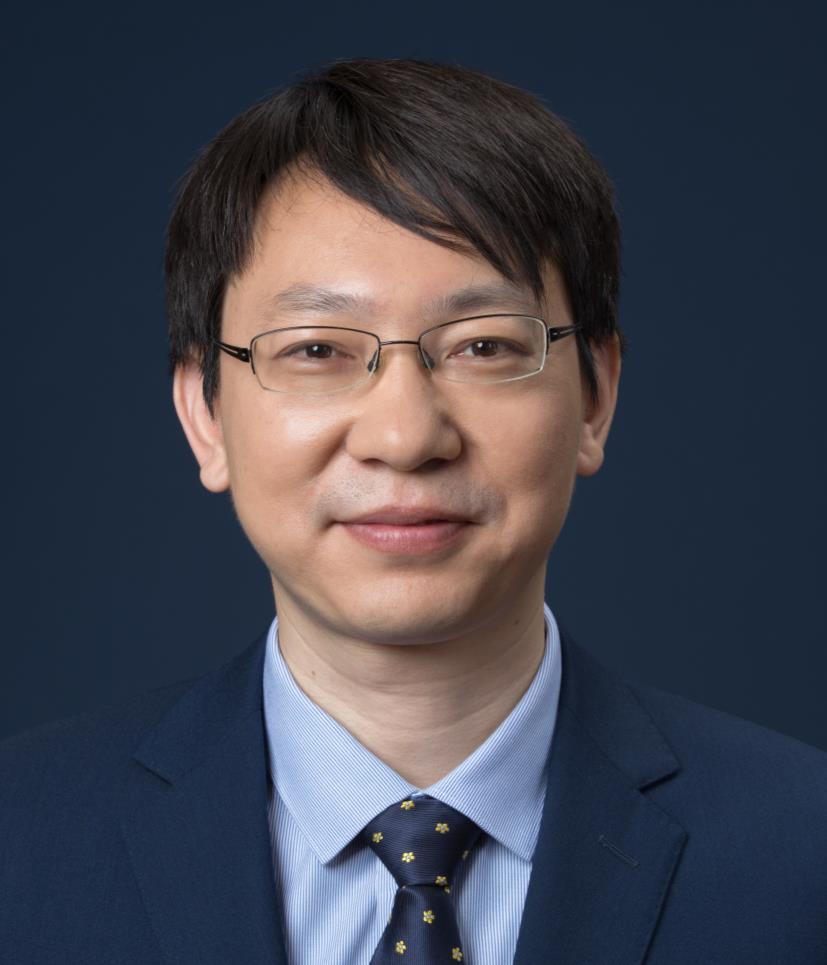
邢登鹏 中国科学院自动化研究所
电子邮件: dengpeng.xing@ia.ac.cn
通信地址: 北京市海淀区中关村东路95号
邮政编码: 100090
电子邮件: dengpeng.xing@ia.ac.cn
通信地址: 北京市海淀区中关村东路95号
邮政编码: 100090
研究领域
机器人控制,类脑智能,因果强化学习
招生信息
希望招收能对科研保持激情、有志于脚踏实地做出带有自己标签的学术成就的学生;同时也希望你具有较好的编程能力和数学功底。
招生专业
081101-控制理论与控制工程081104-模式识别与智能系统
招生方向
机器人控制类脑智能因果强化学习
教育背景
2008-12--2009-12 美国卡内基梅隆大学机器人所 访问学者2006-03--2010-07 上海交通大学自动化系 工学博士2003-09--2006-03 天津大学机械制造及其自动化系 工学硕士1998-09--2002-07 天津大学机械电子工程系 工学学士
工作经历
工作简历
2022-11~现在, 中国科学院自动化研究所, 研究员2013-10~2022-10,中国科学院自动化研究所, 副研究员2012-11~2013-10,中国科学院自动化研究所, 助理研究员2010-11~2012-11,上海交通大学, 博士后
教授课程
机器人学机器人机构学机器人学导论
专利与奖励
专利成果
( 1 ) 模型迁移方法、装置, 发明专利, 2021, 第 1 作者, 专利号: 202111206993.4( 2 ) 机器人控制方法、装置、电子设备及存储介质, 发明专利, 2021, 第 1 作者, 专利号: 202111122532.9( 3 ) 一种机器人控制方法、装置及存储介质, 发明专利, 2021, 第 1 作者, 专利号: 202111113736.6( 4 ) 数据集生成方法、装置、电子设备及存储介质, 发明专利, 2021, 第 1 作者, 专利号: 202111105029.2( 5 ) 轮腿机器人的自稳定控制方法、系统、装置, 发明专利, 2020, 第 1 作者, 专利号: CN110764413A( 6 ) 多路真空正、负压输出控制装置, 发明专利, 2014, 第 1 作者, 专利号: CN103499986A( 7 ) 一种多路显微视觉标定系统及方法, 发明专利, 2014, 第 1 作者, 专利号: CN103544701A
出版信息
发表论文
(1) Learning stable subgoal representation in hierarchical reinforcement learning with causal factorization, IEEE TRANSACTIONS ON NEURAL NETWORKS AND LEARNING SYSTEMS, 2026, 第 2 作者 通讯作者(2) Adaptive graph coordination strategy in multi-agent reinforcement learning, IEEE TRANSACTIONS ON GAMES, 2026, 第 3 作者 通讯作者(3) Enhancing exploration and exploitation in hierarchical reinforcement learning with subgoal graph learning, Association for the Advance of Artificial Intelligence, 2026, 第 2 作者 通讯作者(4) Pre-trained dynamics learning of numerous heterogeneous robots and Gen2Real transfer, IEEE Transactions on Cognitive and Developmental Systems, 2025, 第 1 作者 通讯作者(5) Delayed Dynamic Model Scheduled Reinforcement Learning With Time-Varying Delays for Robotic Control, IEEE ROBOTICS AND AUTOMATION LETTERS, 2025, 第 2 作者 通讯作者(6) Latent Landmark Graph for Efficient Explorationexploitation Balance in Hierarchical Reinforcement Learning, MACHINE INTELLIGENCE RESEARCH, 2025, 第 3 作者(7) Guided Proximal Policy Optimization with Structured Action Graph for Complex Decision-making, Guided Proximal Policy Optimization with Structured Action Graph for Complex Decision-making, Machine Intelligence Research, 2025, 第 2 作者(8) A new pre-training paradigm for offline multi-agent reinforcement learning with suboptimal data, IEEE International Conference on Acoustics, Speech and Signal Processing, 2024, 第 3 作者(9) Learning Playing Piano with Bionic-Constrained Diffusion Policy for Anthropomorphic Hand, CYBORG AND BIONIC SYSTEMS, 2024, 第 3 作者(10) Learning causal dynamics models in object-oriented environments, International Conference on Machine Learning, 2024, 第 3 作者 通讯作者(11) Learning top-K subtask planning tree based on discriminative representation pre-training for decision-making, Machine Intelligence Research, 2024, 第 4 作者 通讯作者(12) Enhancing multi-agent coordination via dual-channel consensus, Machine Intelligence Research, 2024, 第 5 作者(13) A Brain-Inspired Approach for Probabilistic Estimation and Efficient Planning in Precision Physical Interaction, IEEE Transactions on Cybernetics, 2023, 第 1 作者(14) Explainable reinforcement learning via a causal world model, International Joint Conference on Artificial Intelligence, 2023, 第 3 作者 通讯作者(15) Task-prompt generalized world model in multi-environment offline reinforcement learning, European Conference on Artificial Intelligence, 2023, 第 6 作者 通讯作者(16) Generalized robot dynamics learning and Gen2Real transfer, IEEE/RSJ International Conference on Intelligent Robots and Systems, 2023, 第 1 作者(17) Efficient hierarchical reinforcement learning via mutual information constrained subgoal discovery, International Conference on Neural Information Processing, 2023, 第 4 作者 通讯作者(18) M3: Modularization for multi-task and multi-agent offline pre-training, International Conference on Autonomous Agents and Multiagent Systems, 2023, 第 6 作者 通讯作者(19) Balancing exploration and exploitation in hierarchical reinforcement learning via latent landmark graphs, International Joint Conference on Neural Networks, 2023, 第 5 作者 通讯作者(20) Offline Pre-trained Multi-agent Decision Transformer, Offline Pre-trained Multi-agent Decision Transformer, 机器智能研究:英文版, 2023, 第 5 作者(21) Filtered Observations for Model-based Multi-agent Reinforcement Learning, European Conference on Machine Learning and Principles and Practice of Knowledge Discovery in Databases, 2023, 第 6 作者 通讯作者(22) Cardsformer: Grounding language to learn a generalizable policy in hearthstone, European Conference on Artificial Intelligence, 2023, 第 4 作者 通讯作者(23) Efficient spatiotemporal transformer for robotic reinforcement learning, IEEE ROBOTICS AND AUTOMATION LETTERS, 2022, 第 2 作者 通讯作者(24) GCS: Graph-Based Coordination Strategy for Multi-Agent Reinforcement Learning, International Joint Conference on Autonomous Agents and Multi-agent Systems (AAMAS), 2022, 第 4 作者(25) A brain-inspired approach for collision-free movement planning in the small operational space, IEEE TRANSACTIONS ON NEURAL NETWORKS AND LEARNING SYSTEMS, 2022, 第 1 作者(26) Learning in bi-level Markov games, International Joint Conference on Neural Networks, 2022, 第 3 作者 通讯作者(27) Learning Multi-agent Action Coordination via Electing First-move Agent, International Conference on Automated Planning and Scheduling, 2022, 第 4 作者 通讯作者(28) Kinematics learning of massive heterogeneous serial robots, International conference on robotics & automation (ICRA), 2022, 第 1 作者(29) Joint Alignment and Simultaneous Insertion of Multiple Objects in Precision Assembly, IEEE TRANSACTIONS ON INDUSTRIAL INFORMATICS, 2021, 第 1 作者(30) Efficient Insertion Strategy for Precision Assembly With Uncertainties Using a Passive Mechanism, IEEE TRANSACTIONS ON INDUSTRIAL INFORMATICS, 2021, 第 1 作者(31) Simultaneous Control in Belief Space for Circular Insertion in Precision Assembly, IEEE TRANSACTIONS ON INDUSTRIAL INFORMATICS, 2021, 第 1 作者(32) Laser Beam Pointing Control With Piezoelectric Actuator Model Learning, IEEE TRANSACTIONS ON SYSTEMS MAN CYBERNETICS-SYSTEMS, 2020, 第 3 作者(33) 面向细长形物体的精密运动规划, Precision movement regulation targeting thin-and-long objects, 华中科技大学学报:自然科学版, 2020, 第 2 作者(34) Coordinated Motion Planning of Independent Manipulators in Precision Manipulation, IEEE TRANSACTIONS ON INDUSTRIAL INFORMATICS, 2020, 第 1 作者(35) Efficient Coordinated Control Strategy to Handle Randomized Inclination in Precision Assembly, IEEE TRANSACTIONS ON INDUSTRIAL INFORMATICS, 2020, 第 1 作者(36) Sensing and Control for Simultaneous Precision Peg-in-Hole Assembly of Multiple Objects, IEEE TRANSACTIONS ON AUTOMATION SCIENCE AND ENGINEERING, 2020, 第 3 作者(37) Efficient Insertion of Multiple Objects Parallel Connected by Passive Compliant Mechanisms in Precision Assembly, IEEE TRANSACTIONS ON INDUSTRIAL INFORMATICS, 2019, 第 1 作者(38) Efficient Insertion of Partially Flexible Objects in Precision Assembly, IEEE TRANSACTIONS ON AUTOMATION SCIENCE AND ENGINEERING, 2019, 第 1 作者(39) Robust Insertion Control for Precision Assembly With Passive Compliance Combining Vision and Force Information, IEEE-ASME TRANSACTIONS ON MECHATRONICS, 2019, 第 2 作者(40) Efficient Collision Detection and Detach Control for Convex Prisms in Precision Manipulation, IEEE TRANSACTIONS ON INDUSTRIAL INFORMATICS, 2018, 第 1 作者(41) An Efficient Insertion Control Method for Precision Assembly of Cylindrical Components, IEEE TRANSACTIONS ON INDUSTRIAL ELECTRONICS, 2017, 第 3 作者(42) Motion Control for Cylindrical Objects in Microscope's View Using a Projection Method-II: Collision Avoidance With Reduced Dimensional Guidance, IEEE TRANSACTIONS ON INDUSTRIAL ELECTRONICS, 2017, 第 1 作者(43) An Active Radial Compliance Method with Anisotropic Stiffness Learning for Precision Assembly, INTERNATIONAL JOURNAL OF PRECISION ENGINEERING AND MANUFACTURING, 2017, 第 3 作者 通讯作者(44) Motion control for cylindrical objects in microscopes’ view using a projection method: I. collision detection and detach control, IEEE TRANSACTIONS ON INDUSTRIAL ELECTRONICS, 2017, 第 1 作者(45) Coordinated Insertion Control for Inclined Precision Assembly, IEEE TRANSACTIONS ON INDUSTRIAL ELECTRONICS, 2016, 第 1 作者(46) Precision Assembly Among Multiple Thin Objects With Various Fit Types, IEEE-ASME TRANSACTIONS ON MECHATRONICS, 2016, 第 1 作者(47) 宏微结合的多机械手微装配机器人系统, 机器人, 2015, 第 2 作者(48) Collision Detection for Blocking Cylindrical Objects, 2015 IEEE/RSJ INTERNATIONAL CONFERENCE ON INTELLIGENT ROBOTS AND SYSTEMS (IROS), 2015, 第 1 作者(49) Joint role exploration in sagittal balance by optimizing feedback gains, ROBOTICA, 2015, 第 1 作者(50) A Sequence of Micro-assembly for Irregular Objects Based on a Multiple Manipulator Platform, 2014 IEEE/RSJ INTERNATIONAL CONFERENCE ON INTELLIGENT ROBOTS AND SYSTEMS (IROS 2014), 2014, 第 1 作者(51) Active Calibration and Its Applications on Micro-operating Platform with Multiple Manipulators, 2014 IEEE INTERNATIONAL CONFERENCE ON ROBOTICS AND AUTOMATION (ICRA), 2014, 第 1 作者(52) Optimal Parametric Controller for Perturbed Balance and Walking, IEEE International Conference on Robotics and Automation (ICRA), 2012, 第 1 作者(53) Robust approach for humanoid joint control based on a disturbance observer, IET CONTROL THEORY AND APPLICATIONS, 2011, 第 1 作者 通讯作者(54) Multiple Balance Strategies for Humanoid Standing Control, Multiple Balance Strategies for Humanoid Standing Control, 自动化学报, 2011, 第 1 作者(55) Walking controllers under perturbations, IEEE International Conference on Systems, Man, and Cybernetics, 2011, 第 1 作者(56) Gain Scheduled Control of Perturbed Standing Balance, IEEE/RSJ International Conference on Intelligent Robots and Systems, 2010, 第 1 作者 通讯作者(57) Controller Parameter Optimization for Multiple Balance Strategies, 29th Chinese Control Conference, 2010, 第 1 作者 通讯作者(58) MOTION GENERATION FOR THE UPPER BODY OF HUMANOID ROBOT, INTERNATIONAL JOURNAL OF HUMANOID ROBOTICS, 2010, 第 1 作者 通讯作者(59) Arm/trunk motion generation for humanoid robot, Arm/trunk motion generation for humanoid robot, 中国科学:信息科学(英文版), 2010, 第 1 作者(60) Motion Generation for the Upper Body of Humanoid Robot, Joint 48th IEEE Conference on Decision and Control (CDC) / 28th Chinese Control Conference (CCC), 2009, 第 1 作者 通讯作者(61) Feedback controller parameter optimization for standing balance, Dynamic Walking, 2009, 第 1 作者
科研活动
科研项目
( 1 ) 对抗演练场人机混合智能进化技术, 负责人, 国家任务, 2023-01--2026-12( 2 ) 面向刚、柔、软体的高柔顺微操作技能学习与控制策略研究, 负责人, 国家任务, 2021-01--2024-12( 3 ) 机器人脉冲神经网络控制, 负责人, 中国科学院计划, 2020-11--2023-10( 4 ) 基于脉冲神经网络的类脑控制研究, 负责人, 中国科学院计划, 2020-08--2022-12( 5 ) 自主智能体灵巧精准操作学习方法研究, 参与, 国家任务, 2019-10--2023-10( 6 ) 基于深度增强学习和技能学习的微装配机器人学习与控制研究, 负责人, 国家任务, 2017-01--2020-12( 7 ) 微装配智能学习与控制策略研究, 负责人, 国家任务, 2014-01--2016-12( 8 ) 异型零件精密微装配设备研制, 参与, 国家任务, 2012-01--2017-12
指导学生
已指导学生
刘希伟 硕士研究生 081101-控制理论与控制工程
李佳乐 硕士研究生 081203-计算机应用技术
余忠蔚 硕士研究生 085404-计算机技术
王开申 硕士研究生 081203-计算机应用技术
管宏阳 硕士研究生 085404-计算机技术
王泽昌 硕士研究生 081203-计算机应用技术
张一博 硕士研究生 081104-模式识别与智能系统
现指导学生
沈思成 博士研究生 081104-模式识别与智能系统
蒲佳明 硕士研究生 081101-控制理论与控制工程
董旭 硕士研究生 085410-人工智能
邵志豪 硕士研究生 081101-控制理论与控制工程
苏琨豪 硕士研究生 081101-控制理论与控制工程
王雯迪 硕士研究生 081203-计算机应用技术
魏昕原 硕士研究生 081100-控制科学与工程